KILLED · Apr 2026 — Jul 2026 · Agentic physical AI
latice
Autonomous ground and air robots for the bed-work small farms cannot hire for. Signed an LOI, built a working rover, then killed it.
2026.07.22 · KILLED · latice · wrong market, right parts
Parameters
- DRIVE
- mecanum, independent per-wheel control
- POSITION
- UWB anchors and on-board vision
- BOARDS
- multi-MCU, KiCad, JLCPCB
- MARKET
- small-acreage specialty produce
- OUTCOME
- killed — wrong market, right parts
What it was
Incumbent capital and better-funded startups already covered nearly every layer of this stack. The remaining differentiation was end-to-end autonomy, and I could not reach it alone at the speed the space was moving. Signed LOI, working rover, wrong market.
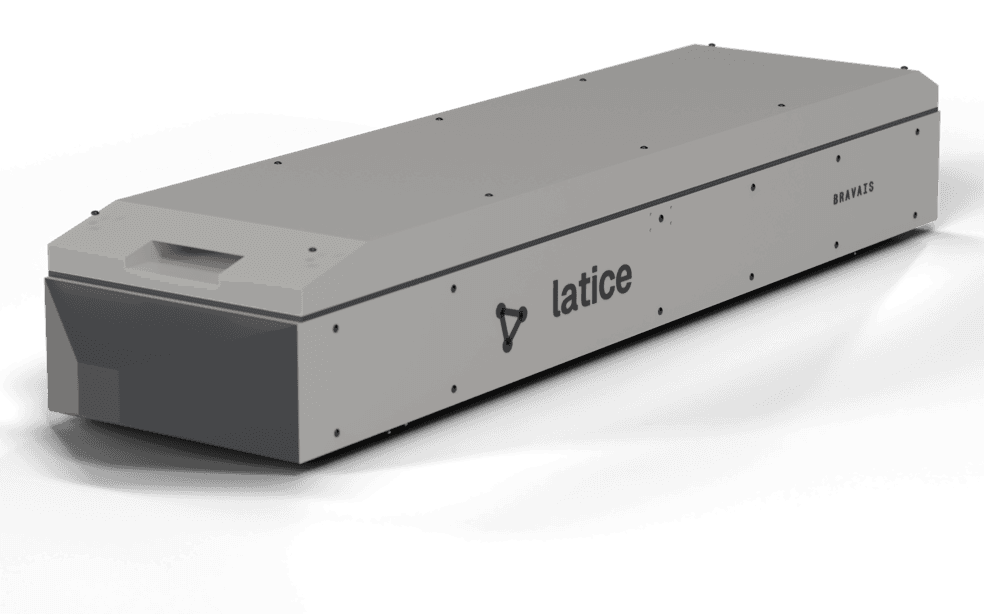
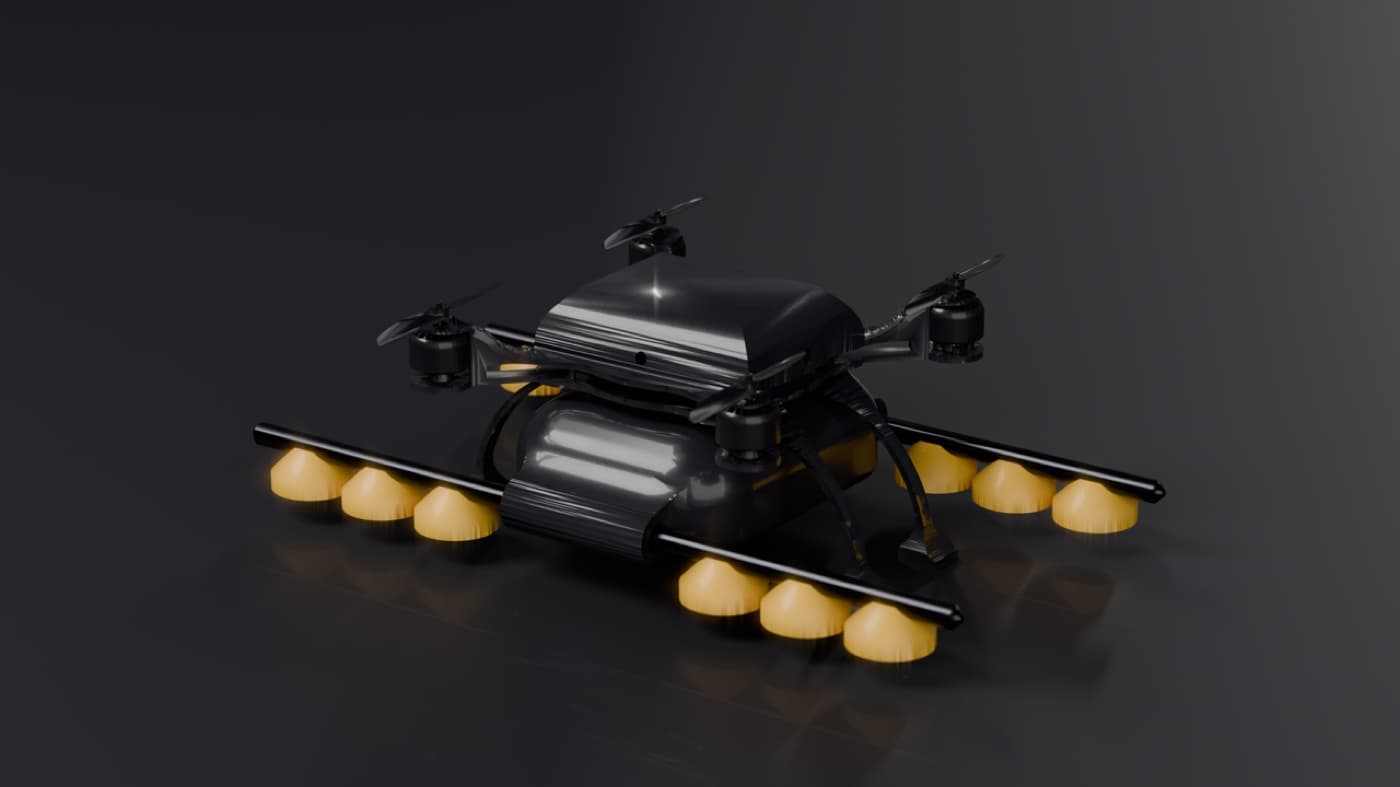
What it was: a sealed mecanum-drive rover that works between the beds, and a spray drone with boom nozzles that treats one bed instead of dousing a field. I designed the enclosures and the boards, wrote the firmware, and tuned the UWB positioning that keeps them on the row. The economics work I did with a New Jersey farm was in labor hours first, dollars second — that framing turned out to be the most portable thing I learned.
Killing it was the right call and it was not a close one by the end. The parts moved forward: the positioning stack, the drive control, the multi-MCU board practice, and the agent orchestration all sit underneath what I am building now.
Carried forward
UWB positioning, mecanum drive control, multi-MCU KiCad boards, and the agent-orchestration layer underneath all of it.
Media
Evidence
- DOCGround rover — CAD render, not a photograph
- DOCSpray drone — CAD render, not a photograph